更多科大概覽

1月8日
3:00pm - 4:00pm
研討會, 演講, 講座

Given a linear control system in a Hilbert space with a bounded control operator, we establish a characterization of exponential stabilizability in terms of an observability inequality. In general, characterizations of stabilization are presented by certain frequency conditions which are in "fequency domain”. Our characterization is given in "time domain". The way to approach the aim is as: we realize that the exponential stabilization is equivalent to a special kind of controllability, and then by the duality argument, it is equivalent to a weak observability inequality.
1月8日
3:00pm - 4:00pm
地點
Room 4502, Academic Building (Lifts 25-26)
講者/表演者
Prof. Gengsheng WANG
Tianjin University
Tianjin University
主辦單位
Department of Mathematics
聯絡方法
mathseminar@ust.com
付款詳情
對象
Alumni, Faculty and Staff, PG Students, UG Students
語言
英語
其他活動
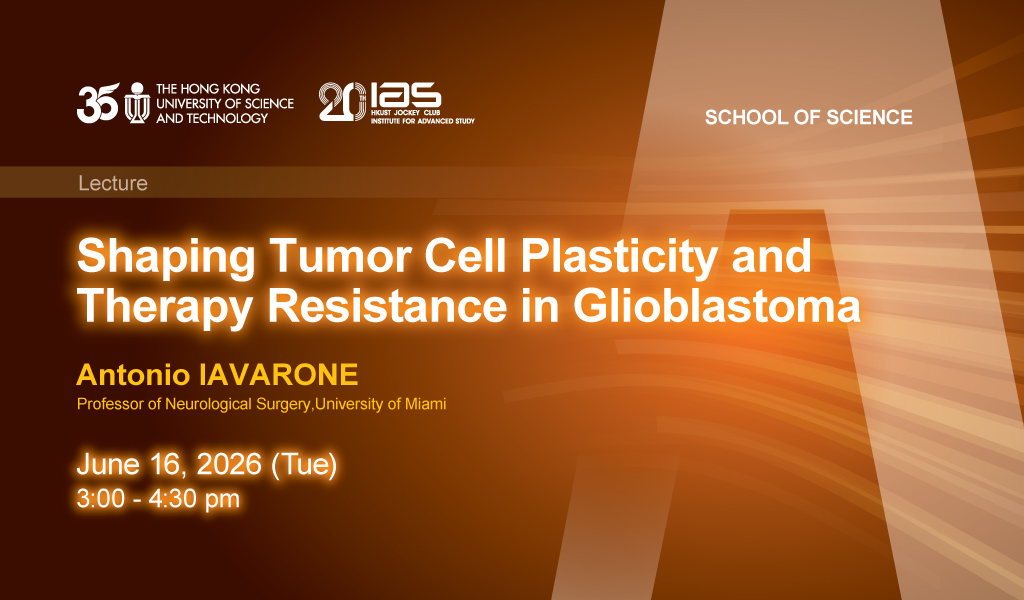
6月16日
研討會, 演講, 講座
IAS / School of Science Joint Lecture - Shaping Tumor Cell Plasticity and Therapy Resistance in Glioblastoma
Abstract
Tumor heterogeneity fueled by plasticity and genetic diversification of cancer cells is key to therapy failure of malignant glioma. The speaker's team implemented spatial and genetic p...