更多科大概覽

1月9日
3:00pm - 4:00pm
研討會, 演講, 講座

There exist many ways to stabilize an infinite-dimensional linear autonomous control systems when it is possible. Anyway, finding an exponentially stabilizing feedback control that is as simple as possible may be a challenge. The Riccati theory provides a nice feedback control but may be computationally demanding when considering a discretization scheme. Proper Orthogonal Decomposition (POD) offers a popular way to reduce large-dimensional systems. In the present paper, we establish that, under appropriate spectral assumptions, an exponentially stabilizing feedback Riccati control designed from a POD finite-dimensional approximation of the system stabilizes as well the infinite-dimensional control system.
1月9日
3:00pm - 4:00pm
地點
Room 4502, Academic Building (Lifts 25-26)
講者/表演者
Prof. Gengsheng WANG
Tianjin University
Tianjin University
主辦單位
Department of Mathematics
聯絡方法
mathseminar@ust.com
付款詳情
對象
Alumni, Faculty and Staff, PG Students, UG Students
語言
英語
其他活動
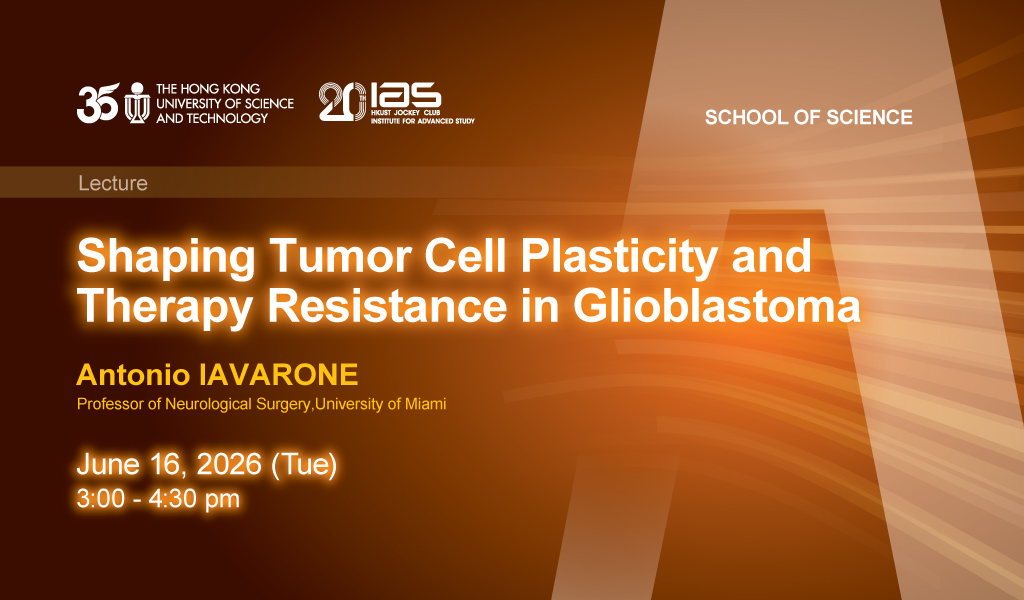
6月16日
研討會, 演講, 講座
IAS / School of Science Joint Lecture - Shaping Tumor Cell Plasticity and Therapy Resistance in Glioblastoma
Abstract
Tumor heterogeneity fueled by plasticity and genetic diversification of cancer cells is key to therapy failure of malignant glioma. The speaker's team implemented spatial and genetic p...