More about HKUST

9 Jan 2020
3:00pm - 4:00pm
Seminar, Lecture, Talk

There exist many ways to stabilize an infinite-dimensional linear autonomous control systems when it is possible. Anyway, finding an exponentially stabilizing feedback control that is as simple as possible may be a challenge. The Riccati theory provides a nice feedback control but may be computationally demanding when considering a discretization scheme. Proper Orthogonal Decomposition (POD) offers a popular way to reduce large-dimensional systems. In the present paper, we establish that, under appropriate spectral assumptions, an exponentially stabilizing feedback Riccati control designed from a POD finite-dimensional approximation of the system stabilizes as well the infinite-dimensional control system.
9 Jan 2020
3:00pm - 4:00pm
Where
Room 4502, Academic Building (Lifts 25-26)
Speakers/Performers
Prof. Gengsheng WANG
Tianjin University
Tianjin University
Organizer(S)
Department of Mathematics
Contact/Enquiries
mathseminar@ust.com
Payment Details
Audience
Alumni, Faculty and Staff, PG Students, UG Students
Language(s)
English
Other Events
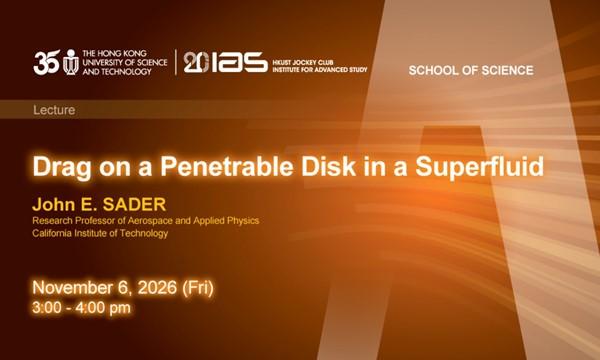
6 Nov 2026
Seminar, Lecture, Talk
IAS/ School of Science Joint Lecture - Drag on a Penetrable Disk in a Superfluid
Abstract
The motion of a body through a superfluid can generate phenomena distinct from a normal viscous fluid. This includes the absence of drag below a critical body speed with the shedding o...
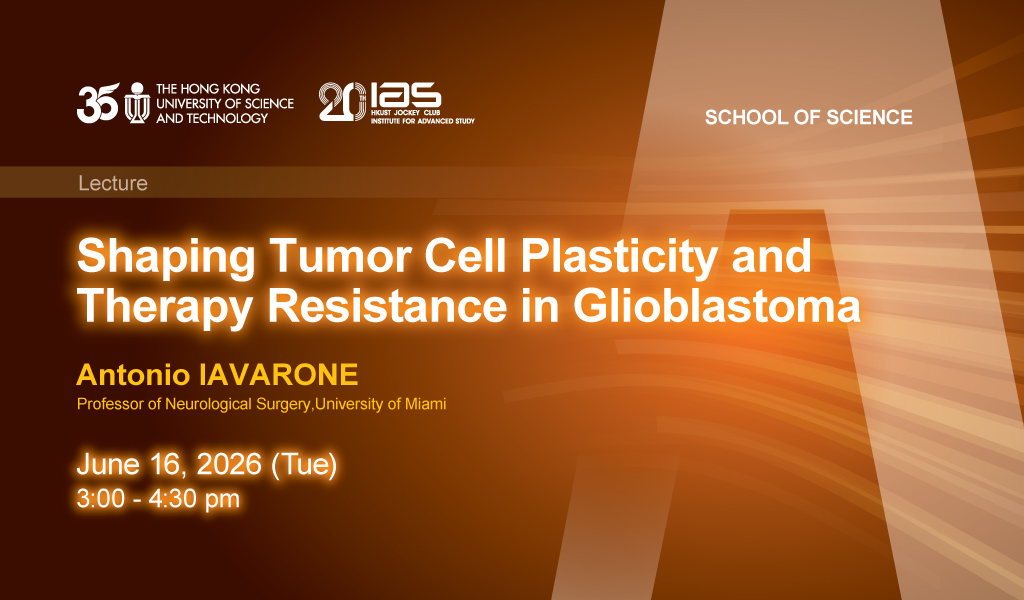
16 Jun 2026
Seminar, Lecture, Talk
IAS / School of Science Joint Lecture - Shaping Tumor Cell Plasticity and Therapy Resistance in Glioblastoma
Abstract
Tumor heterogeneity fueled by plasticity and genetic diversification of cancer cells is key to therapy failure of malignant glioma. The speaker's team implemented spatial and genetic p...